Every month dozens of papers that use Unitree robots appear on arXiv. Most of them matter only to researchers. We have kept twelve that meet three conditions: they use a real robot or a faithful simulation, they say something to anyone deciding on a purchase or a project, and they can be cited in a tender specification.
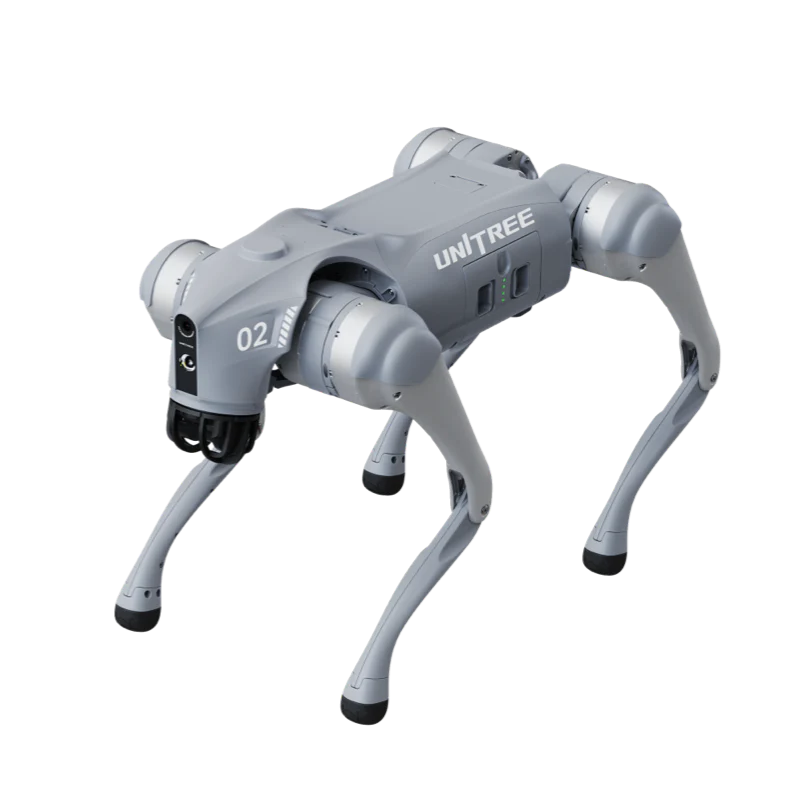
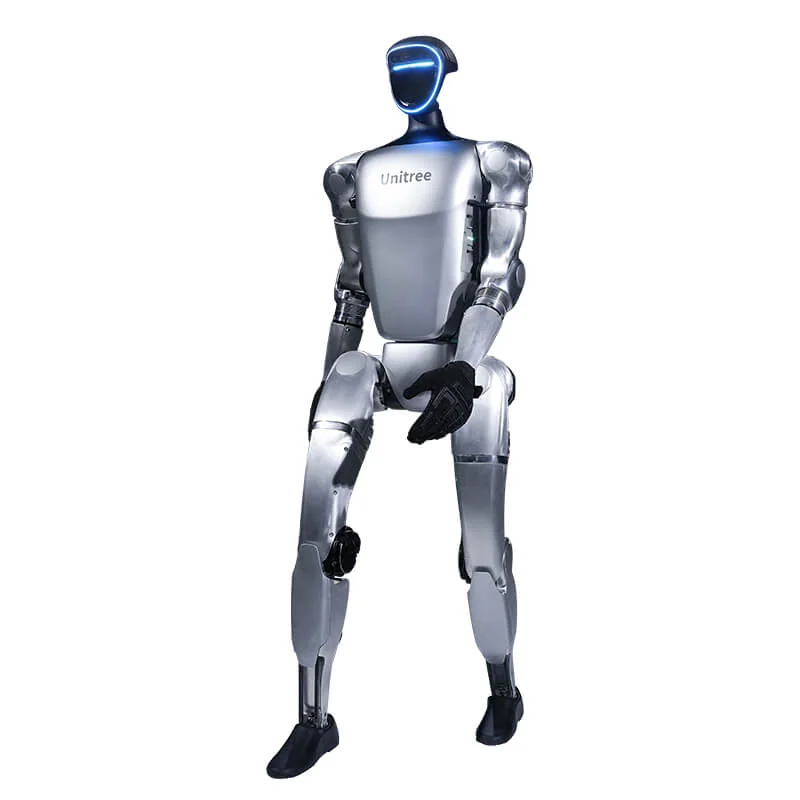
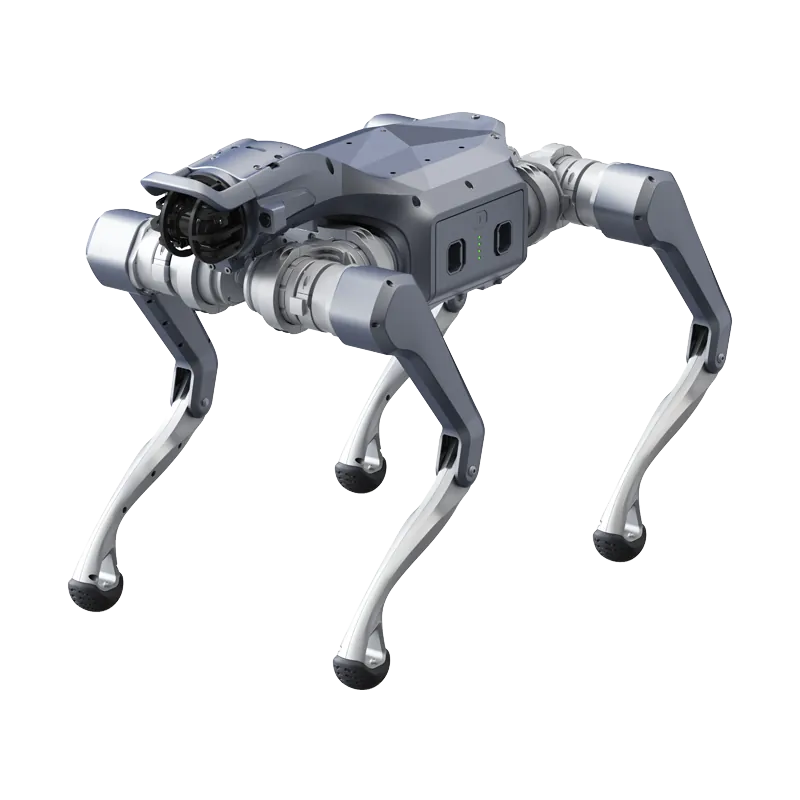
Almost all of them use a Go2 or a G1, and running your own code on the robot requires the EDU versions, with the SDK. The methods also apply to the AS2 and H2, but the numbers must be measured again on the robot you buy.
Quadrupeds: locomotion and transfer from simulation
Gaits that cope with a failed joint
AcL (arXiv:2503.21401) uses reinforcement learning to train gaits that hold up with up to four unpowered joints, on one or two legs, and tests them on a real Go2 with one and two failed joints.
In practice: for an inspection robot, how it behaves when a motor fails mid-route can be measured and included in the acceptance tests.
Predicting real behaviour before the trial
MoE + RoboGauge (arXiv:2602.00678) combines several specialised controllers and proposes metrics that predict how well a policy trained in simulation will hold up on the robot. The Go2 is tested on snow, sand, stairs, slopes and 30 cm obstacles, and reaches 4 m/s in the speed tests.
In practice: weak policies can be weeded out in simulation, before a risky physical trial. This helps anyone developing in-house on the EDU version.
Lightweight policies for those with few GPUs
RANDPOL (arXiv:2505.19054) trains only the last layer of a policy whose hidden layers are random and fixed, and transfers it to the real Go2 without further tuning.
In practice: a lab with limited computing resources can still do end-to-end control on the Go2 EDU.
Floors that vibrate
Bridge the Gap (arXiv:2510.13488) trains the Go2 in MuJoCo on a 13.24 m oscillating bridge and tests it on the real bridge: vertical perturbations during training make the gait more stable.
In practice: walkways and vibrating floors in a plant are not normal terrain. If the route includes them, say so before choosing the robot.
Quadrupeds: navigation and datasets
Ready-made trajectories for imitation learning
Kine2Go (arXiv:2606.14433) publishes 800 kinematic trajectories of the Go2 generated by 40 different policies.
In practice: anyone starting imitation learning from scratch has a reference dataset without having to record everything on their own robot.
Autonomous navigation in a library
Li et al. (arXiv:2606.03340) put ROS 2, RTAB-Map and Nav2 on a Go2 EDU and run it in a real library: 100% of routes completed with a static scene, 96% with a few people moving about, 88% with many, mean map error 3.7 cm.
In practice: it is the closest reference to an indoor patrol in a warehouse or a corridor. The drop with people moving about is the number to keep in mind.
When the robot gets stuck in vegetation
ForEnt (arXiv:2606.19675) is a dataset collected with a Go2 in eight woodland sites around Southampton, in the United Kingdom: about 1.7 km covered and 69 cases in which the robot's legs got caught in vegetation.
In practice: in undergrowth the Go2 gets its legs caught and can tip over. That kind of route needs field trials and a dedicated risk assessment.
Moving among people
Wu et al. (arXiv:2607.15036) navigate a real Go2 through crowds, indoors and outdoors, using only the onboard LiDAR and a method that estimates safe velocities with respect to moving obstacles.
In practice: trade shows, warehouses and areas with operators are a separate case from an empty route. It has to be tested with real people.
Humanoids: energy, teleoperation and foundation models
How much power a G1 arm draws
Deniz et al. (arXiv:2606.15915) build a physics-based model of the electrical power consumption of the G1's 7-degree-of-freedom left arm. The model explains 93% of the variance in the identification data and over 96% at speeds not used to build it.
In practice: for prolonged manipulation the declared runtime is not enough. With a power model you can plan motion around energy as well.
Whole-body teleoperation with a sensor suit
Durrani and Khan (arXiv:2605.12347) drive a G1 in real time with an IMU-based motion capture suit, first in MuJoCo and then on the robot without changes.
In practice: every teleoperation demo, on an H2 too, has to deal with the same problems: retargeting the movements to the robot, latency, sensor drift and the gap between simulation and reality.
Fine-tuning a foundation model
Park, Kee and Oh (arXiv:2512.01358) refine a foundation policy by adding contact signals: on the G1 the task "pick up the apple and put it in the bowl" succeeds 0% of the time without fine-tuning, 48% with standard fine-tuning and 94% with contact force data.
In practice: a foundation model works after fine-tuning on your own data, not straight out of the box. That is the right context in which to read the claims about the H2 Plus and Isaac GR00T.
What really counts in motion tracking
Amadio and Mingo Hoffman (arXiv:2607.19903) compare, on the G1 and with the open-source YAHMP framework, six design choices in the tracking of human movements, including how commands and actions are represented and the observation history.
In practice: some choices change tracking quality, others only actuator effort or training complexity. Check them before blaming the hardware for a poor demo.
How to use this list
- Before buying. Choose the paper you want to reproduce: the robot the authors used sets the minimum configuration, almost always a Go2 EDU or G1 EDU.
- In the tender specification. Cite two or three papers as a technical basis, not as a performance guarantee.
- In the PoC. Use the metrics from the papers (success rate, operator interventions, power consumption) as indicators to measure on your own setup. The method is in the guide to a PoC with a humanoid.
For your first steps with the software there is the guide to ROS 2 on Unitree.
Frequently asked questions
Do the paper results also apply to the AS2 and H2?
Not directly. Almost all the papers use the Go2 and G1: the methods and metrics can be reused, but the numbers must be measured again on your robot.
Do you need an EDU version to reproduce these papers?
Usually yes: running your own code on the robot requires the SDK and the onboard computing of the EDU versions.
Are arXiv preprints reliable?
They are papers that have not yet been peer-reviewed, or are not in their final version. Check the figures and experimental conditions in the PDF before using them in a project.
Abra Robotics sells Unitree hardware and integration services in the UK, Ireland and internationally, and is not the author of the papers cited.